Ros Package Template
A ros driver for orbbec 3d cameras. Please ask questions on answers.ros.org. To open a rosbuild ros package code as a project, use open file or project and select the cmakelists.txt of your ros package. Please refer directly to ros wiki.; The template could for example contain the license header, author name, and include guards (in case of a header file).
Ros Package Template - This tutorial covers the toolchain to build a package. The template could for example contain the license header, author name, and include guards (in case of a header file). To open a rosbuild ros package code as a project, use open file or project and select the cmakelists.txt of your ros package. We would like to show you a description here but the site won’t allow us. A ros driver for orbbec 3d cameras. The package was developed by charles river analytics, inc. Robot_localization is a package of nonlinear state estimation nodes. This tutorial introduces ros graph concepts and discusses the use of roscore, rosnode, and rosrun. Please refer directly to ros wiki.; This package supports ros kinetic, melodic and noetic distributions.
Ros Package Template Gallery
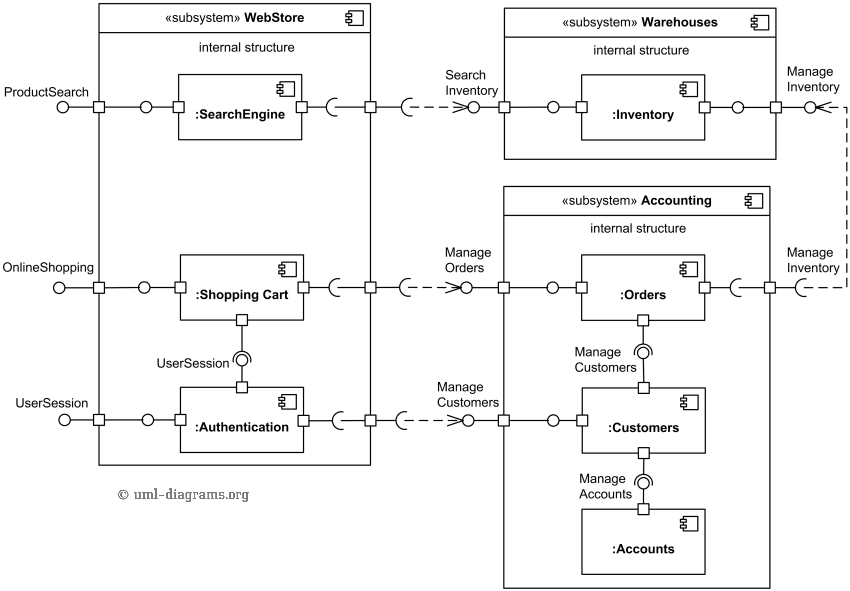
Contoh Interface Database Contoh Ros
This tutorial covers the toolchain to build a package. A ros driver for orbbec 3d.
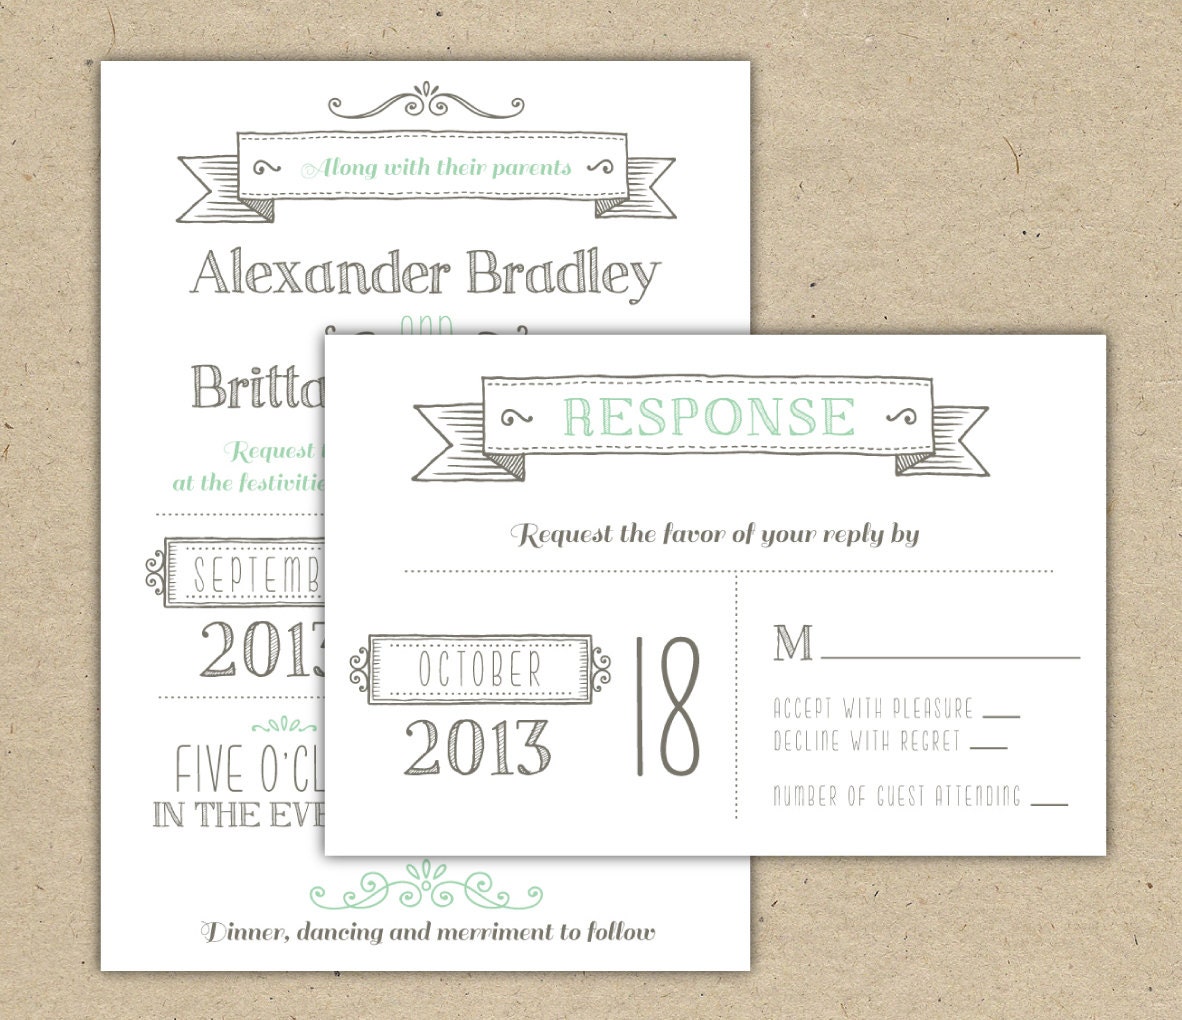
Wedding Invitation 1041 SAMPLE. Modern invitation template.
The template could for example contain the license header, author name, and include guards (in.

ROS put out a package pickup reminder for their residents Take this
The template could for example contain the license header, author name, and include guards (in.
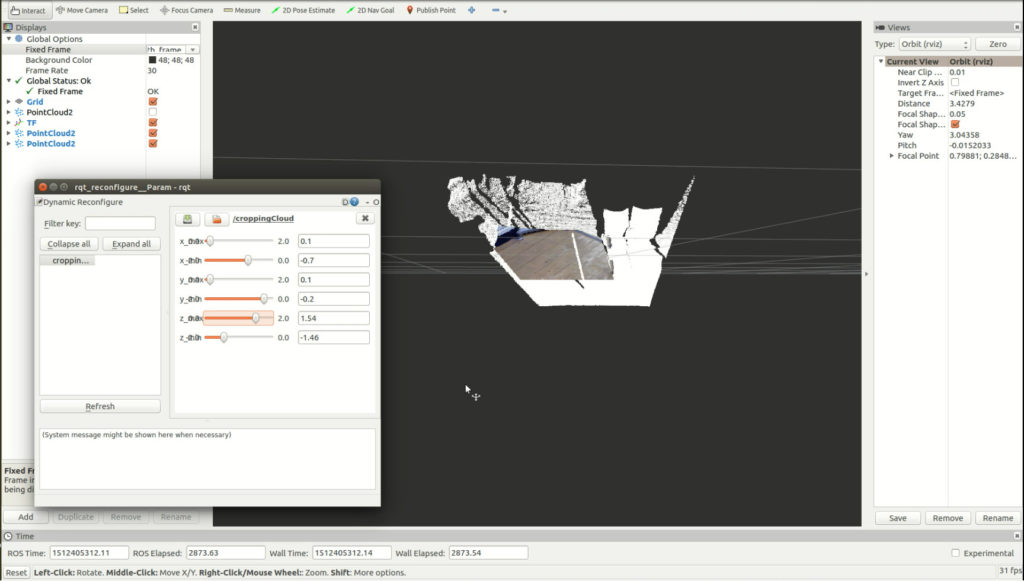
A GUI ROSpackage for cropping pcl pointcloud with dynamic reconfigure
The template could for example contain the license header, author name, and include guards (in.
Overleaf Beamer Template Metropolis The Best Picture Of Beam
Please ask questions on answers.ros.org. Please refer directly to ros wiki.; The package was developed.
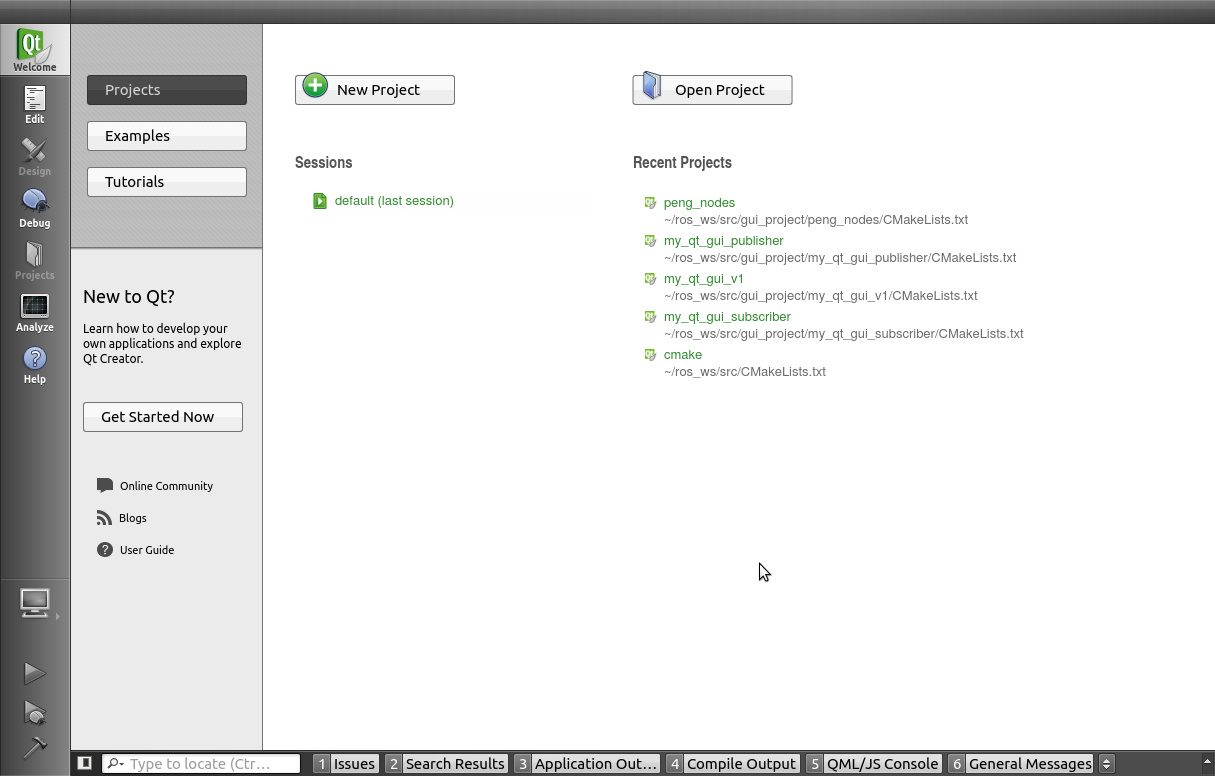
[Tutorial] How to build a GUI in ROS with Qt / C++? CasperWin 博客园
This package supports ros kinetic, melodic and noetic distributions. A ros driver for orbbec 3d.
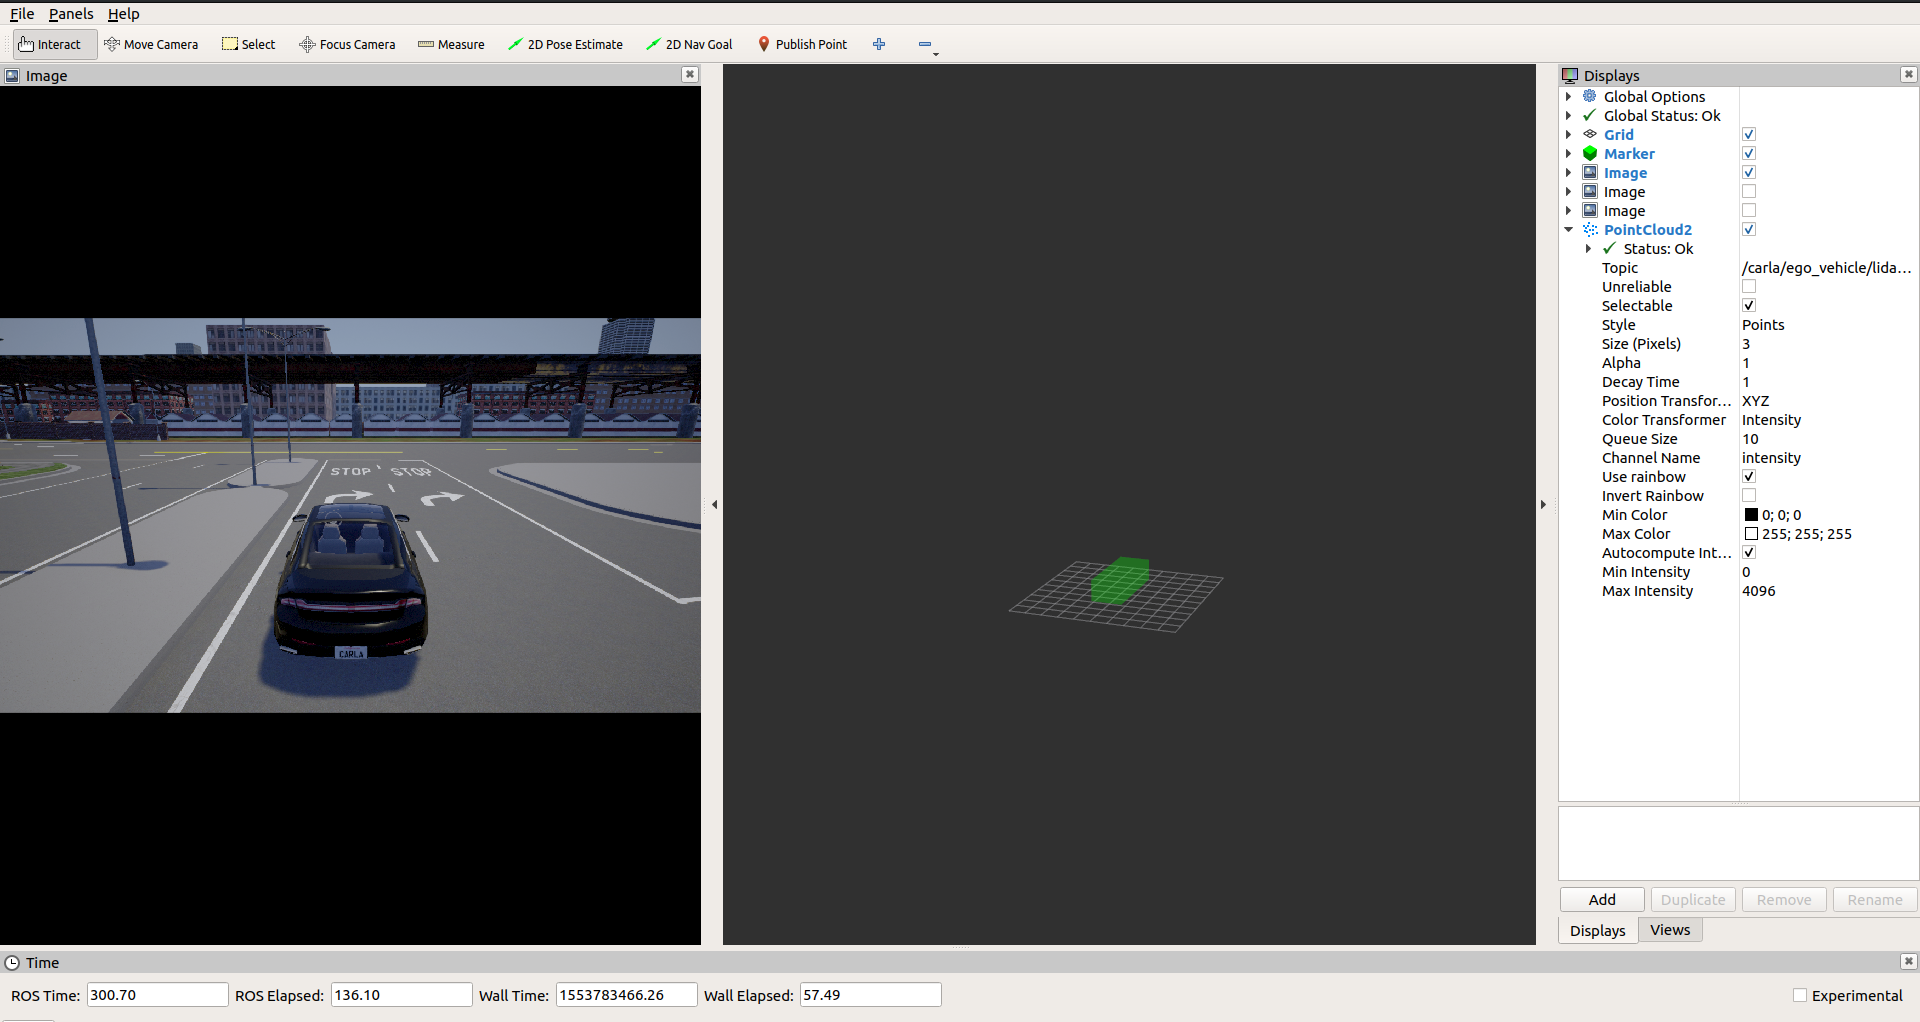
ROSCARLA Integration > How to use ROS Bridge package
This tutorial introduces ros graph concepts and discusses the use of roscore, rosnode, and rosrun..
Radio advertising
Robot_localization is a package of nonlinear state estimation nodes. To open a rosbuild ros package.
The template could for example contain the license header, author name, and include guards (in case of a header file). This package supports ros kinetic, melodic and noetic distributions. This tutorial covers the toolchain to build a package. Please refer directly to ros wiki.; We would like to show you a description here but the site won’t allow us. Robot_localization is a package of nonlinear state estimation nodes. A ros driver for orbbec 3d cameras. Please ask questions on answers.ros.org. This tutorial introduces ros graph concepts and discusses the use of roscore, rosnode, and rosrun. The package was developed by charles river analytics, inc. To open a rosbuild ros package code as a project, use open file or project and select the cmakelists.txt of your ros package.
A Ros Driver For Orbbec 3D Cameras.
To open a rosbuild ros package code as a project, use open file or project and select the cmakelists.txt of your ros package. The template could for example contain the license header, author name, and include guards (in case of a header file). Please refer directly to ros wiki.; The package was developed by charles river analytics, inc.